Original Industrial Spare Part
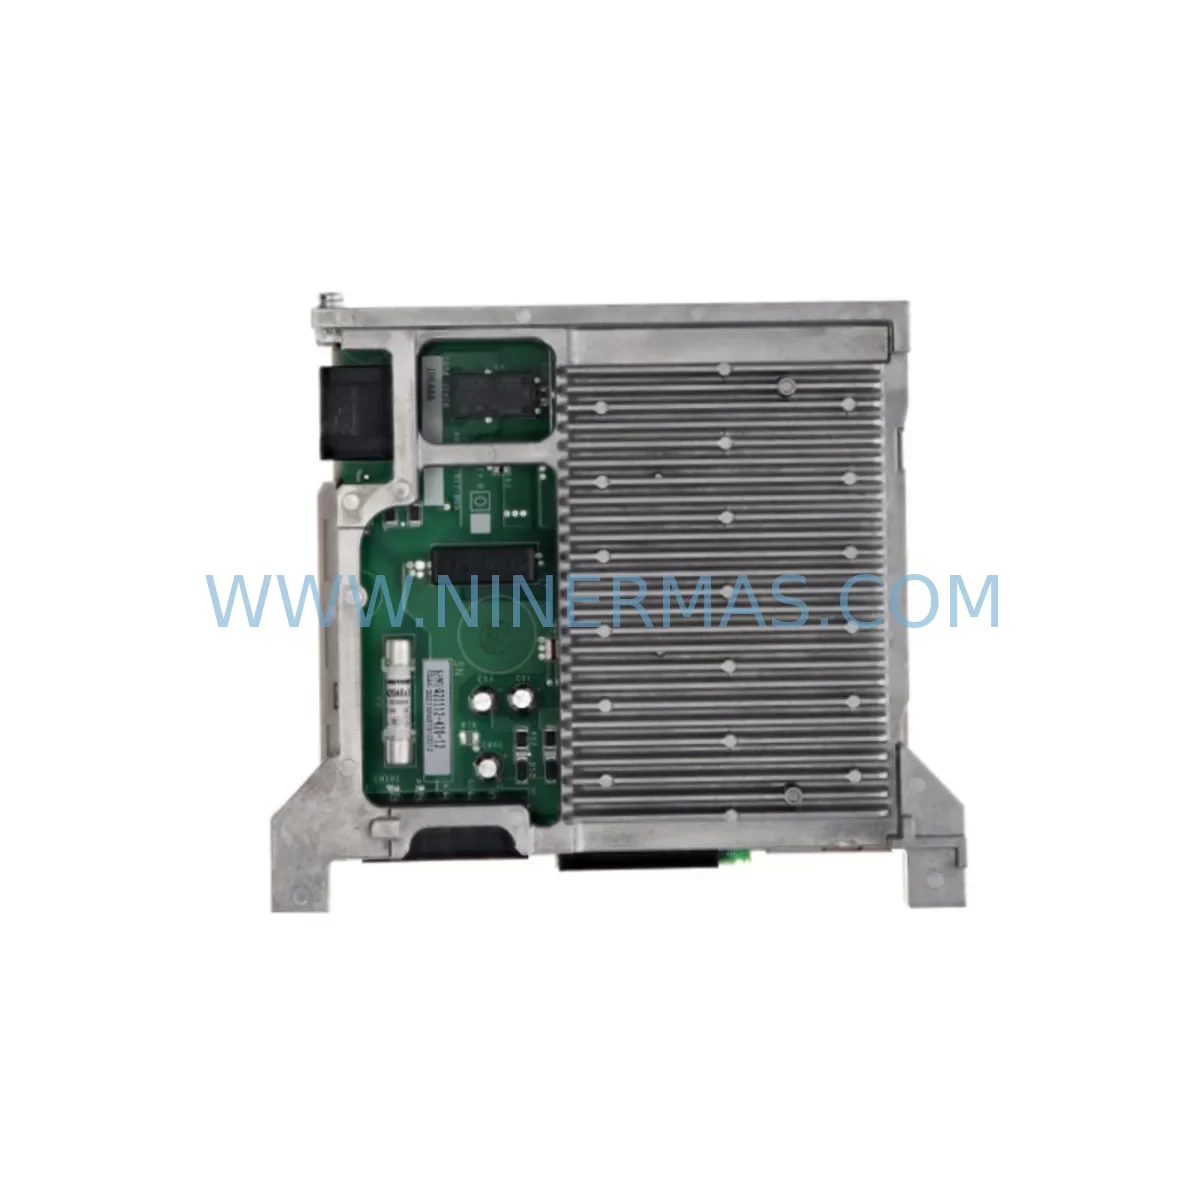
Yaskawa JANCD-ASF01-E Retrofit Servo Board for Legacy Systems
Verify the part, confirm the platform family, and move straight into quotation with the right commercial details.
RFQ Ready
- SKUYRC1000 JANCD-ASF01-E GWA 180/210/240 00109363 SRDA-MH6 , SRDA-C0A12A01A-E
- CategoryPLC & Industrial Automation Modules
- BrandYASKAWA
- SupportAvailability, lead time, condition, and shipping coordination
How Buyers Usually Use This Page
- Confirm the exact part number and platform family before sending the quote request.
- Use direct email when quantity, condition, and destination are already defined internally.
- Switch to the broader brand or category archive when you need alternates nearby.
Series Navigation
Move through the most common platform families behind this part.
Product RFQ
Send this part directly for quotation.
Include quantity, required condition, destination country, and target delivery timing. Current reference: Yaskawa JANCD-ASF01-E Retrofit Servo Board for Legacy Systems with SKU YRC1000 JANCD-ASF01-E GWA 180/210/240 00109363 SRDA-MH6 , SRDA-C0A12A01A-E.
Yaskawa JANCD-ASF01-E Retrofit Servo Board for Legacy Systems
The Yaskawa JANCD-ASF01-E is a servo control board designed for the YRC1000 robot controller platform, widely deployed across automotive assembly lines, arc welding cells, material handling systems, and general-purpose industrial automation. As production environments age and original spare parts become increasingly difficult to source, the JANCD-ASF01-E has emerged as a critical retrofit-compatible component for facilities seeking to extend the operational life of their Yaskawa robot installations without committing to a full controller replacement. This board supports direct installation into existing YRC1000 controller cabinets, preserving original program logic, axis configurations, and communication parameters established during initial commissioning.
Facilities operating legacy Yaskawa robot systems frequently encounter situations where the original JANCD-ASF01-E board has failed due to capacitor aging, thermal stress, or power surge events. In these cases, sourcing a verified replacement with pre-shipment functional testing is essential to minimizing unplanned downtime. NINERMAS maintains reserved inventory of the JANCD-ASF01-E to support urgent replacement requirements, with a 12-month warranty covering all supplied units. Each board undergoes bench-level verification prior to dispatch, confirming servo axis communication integrity, encoder feedback signal processing, and backplane interface continuity.
Upgrade Compatibility Table
| Parameter | JANCD-ASF01-E Specification | Retrofit Notes |
|---|---|---|
| Compatible Controller | Yaskawa YRC1000 | Direct slot replacement; no mechanical modification required |
| Backplane Interface | YRC1000 internal bus connector | Verify connector pin alignment before insertion |
| Servo Axis Support | Up to 6 axes (robot) + external axes | Confirm axis address mapping matches original configuration |
| Encoder Feedback | Serial encoder (Yaskawa proprietary) | Compatible with SGMJV, SGMGV, and SGMCS motor series |
| Communication Protocol | MECHATROLINK-II / internal YRC1000 bus | No protocol reconfiguration required for same-series replacement |
| Power Supply Requirement | Supplied via YRC1000 backplane (24VDC logic) | Verify PSU output stability before board installation |
| Installation Space | Standard YRC1000 board slot | Confirm no adjacent board interference |
| Firmware Compatibility | YRC1000 system software dependent | Match firmware revision to existing controller version |
| Warranty | 12 Months | Covers manufacturing defects; pre-shipment tested |
Retrofit Planning for Existing Automation Systems
When planning a JANCD-ASF01-E replacement within an active production environment, engineers must account for several interdependent system elements to ensure a smooth transition. The YRC1000 controller cabinet typically houses multiple boards in a defined slot arrangement, including the JANCD-MIF01-E main CPU board, the JANCD-AIF01-E analog I/O interface board, and the JANCD-MSV01-E safety monitoring board. Before removing the failed JANCD-ASF01-E, technicians should document the current slot position, cable routing, and any axis-specific parameter files stored in the controller’s non-volatile memory.
Power supply integrity is a prerequisite for successful board replacement. The YRC1000 internal power distribution relies on the JZRCR-YPU01-1 power unit to deliver regulated DC voltages to all installed boards. If the power unit shows signs of output ripple or voltage deviation, it should be inspected or replaced concurrently with the servo board to prevent repeat failures. Similarly, the SGDV-2R8A01A or equivalent Yaskawa Servopack amplifier connected to the servo axes should be verified for correct parameter settings, particularly speed loop gain, position loop gain, and encoder resolution, which must align with the replacement JANCD-ASF01-E configuration.
Communication continuity is another critical factor. The YRC1000 platform uses a proprietary internal communication bus to coordinate between the servo board, the main CPU, and peripheral I/O modules. If the system also interfaces with external PLCs or SCADA systems via the JUSP-NS100 network interface unit or the JANCD-AEW02-E Ethernet board, these communication links must be verified post-installation to confirm that robot status signals, alarm outputs, and remote start/stop commands are functioning correctly. HMI screens configured to display axis position data or alarm codes should be tested against live controller output after the replacement board is initialized.
For systems that include external servo axes — such as positioners or linear tracks controlled via the JZRCR-NPP01B-1 external axis interface — axis address assignments must be confirmed in the controller’s system parameters before resuming automatic operation. Incorrect axis addressing can result in motion faults or unintended axis movement during the first program execution cycle. A controlled jog test of each axis at reduced speed is recommended before returning the cell to full production speed.
The HW9381613-A wiring harness assembly, commonly used in YRC1000 installations, should be inspected for connector wear or insulation damage during the board replacement procedure. Damaged wiring in close proximity to the servo board can introduce intermittent faults that are difficult to diagnose after reassembly. Replacing worn harness sections during the planned maintenance window reduces the risk of secondary failures in the weeks following the retrofit.
Downtime Control During System Migration
Minimizing downtime during a JANCD-ASF01-E replacement requires advance preparation and a structured execution sequence. Before the maintenance window begins, all relevant controller parameters should be backed up using the YRC1000 programming pendant or the MotoSim offline programming environment. This backup captures job files, system parameters, axis calibration data, and I/O assignments, ensuring that the replacement board can be initialized with the exact configuration of the original unit.
The physical replacement procedure for the JANCD-ASF01-E is straightforward when the controller is de-energized and lockout/tagout procedures are followed. The board is secured within the YRC1000 chassis by a standard retention mechanism, and all connectors are keyed to prevent incorrect insertion. After installing the replacement board, the controller should be powered on in maintenance mode to allow the system software to recognize the new hardware before transitioning to normal operating mode.
Parameter restoration from the backup file should be performed immediately after the board is recognized by the controller. Axis zero-point calibration may be required if the replacement board does not retain the original encoder reference data. This calibration step typically requires 30 to 60 minutes per robot axis and should be factored into the planned maintenance window. Once calibration is complete, a full cycle test at reduced speed confirms that all axes respond correctly to program commands before production speed is restored.
NINERMAS supports urgent replacement scenarios with same-day dispatch for in-stock JANCD-ASF01-E units, reducing the total time from fault identification to board installation. The 12-month warranty on all supplied units provides ongoing assurance that the replacement component meets the reliability standards required for continuous production environments.
Retrofit Support FAQ
Q: Is the JANCD-ASF01-E a direct replacement for the original board in the YRC1000 controller?
A: Yes. The JANCD-ASF01-E supplied by NINERMAS is a verified replacement for the original Yaskawa part. It installs into the same slot position within the YRC1000 chassis without mechanical modification. Pre-shipment functional testing confirms servo axis communication and encoder feedback signal integrity before dispatch.
Q: What commissioning steps are required after installing the replacement JANCD-ASF01-E?
A: After installation, restore the controller parameter backup via the programming pendant. Verify axis address assignments, confirm encoder reference data, and perform a zero-point calibration if required. Test all axes at reduced speed before returning the system to full production operation. Communication links to external PLCs or HMI systems should also be verified.
Q: Can the JANCD-ASF01-E be used with Yaskawa servo motors from the SGMJV or SGMGV series?
A: Yes. The JANCD-ASF01-E supports Yaskawa serial encoder feedback compatible with the SGMJV, SGMGV, and SGMCS motor series. Confirm that the encoder resolution and motor parameter settings in the YRC1000 system parameters match the connected motor specifications before enabling servo operation.
Q: What warranty and inventory support does NINERMAS provide for the JANCD-ASF01-E?
A: NINERMAS provides a 12-month warranty on all JANCD-ASF01-E units, covering manufacturing defects identified under normal operating conditions. Reserved inventory is maintained to support urgent replacement requirements. Each unit is pre-shipment tested to confirm functional integrity. Contact our technical team for lead time confirmation and long-term supply agreements.
| Product Series | Legacy |
|---|---|
| Country of Origin | JP |
Catalog Continuation
More YASKAWA modules in the catalog.
Use the brand lane to compare nearby part numbers, platform-adjacent modules, and other inquiry-ready listings before sending your final RFQ.
SKU: HW0388706-A HW0388708-A HW0388710-A
Yaskawa HW0388706-A Retrofit Servo Board for Legacy Systems
SKU: DX100 SRDA-EAXA01A
Yaskawa SRDA-EAXA01A Retrofit Servo Drive for Legacy Systems
SKU: SGMRV-13ANA-YR1D
Yaskawa SGMRV-13ANA-YR1D Retrofit AC Servo for Legacy Systems
SKU: CP-9200SH/ DDCP-921311
Yaskawa DDCP-921311 Retrofit CPU Controller for Legacy Systems
Catalog Continuation
Alternative parts within PLC & Industrial Automation Modules.
Stay inside the same system family when you need substitutes, adjacent modules, or a broader shortlist for procurement review.
SKU: HDD02.2-W040N-HS12-01-FW FWA-DIAX04-ELS-05VRS-MS
Rexroth HDD02.2-W040N-HS12-01-FW Service-Ready Spare Part
SKU: I5DAE375F10010000S
Lenze I5DAE375F10010000S Service-Ready Spare Part for Industrial Maintenance